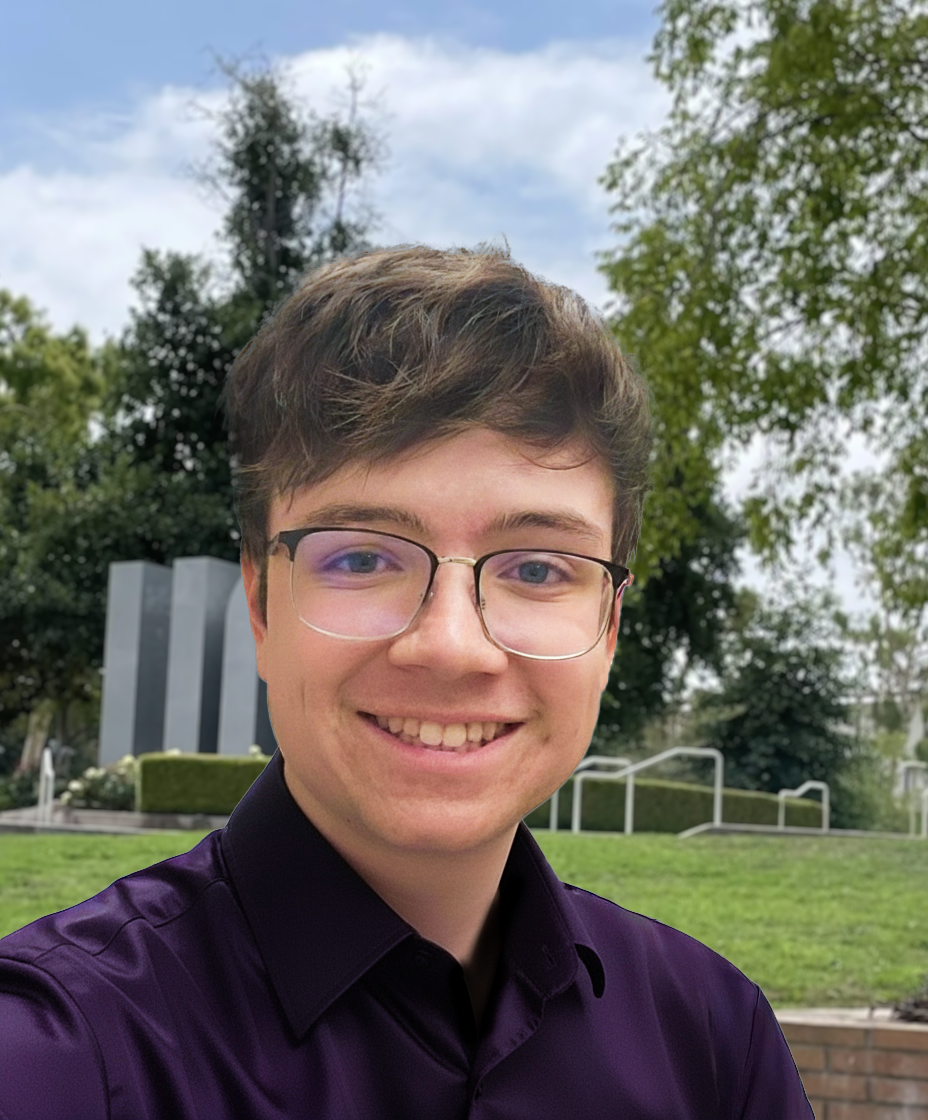
SUMMARY
Hello! I'm a Computer Science student at the University of California, San Diego with a strong interest in software engineering, AI, and full-stack development. I’m always seeking new opportunities to apply my skills and take on meaningful projects.
I am currently working on
My resume can be found here
Projects
LEADERSHIP

Research Intern
Collaborative Intelligence Systems Lab
Jun 2026 - Present
- Reverse-engineered a commercial-grade differential-drive robot's undocumented interfaces for use on UCR's campus, gaining full control of sensor and control pipelines built around MPC-based obstacle avoidance
- Deployed a full end-to-end indoor autonomous navigation stack, building a custom LiDAR map with FAST-LIO, and achieving 95% goal-reaching success rate over 40 trials
- Built an outdoor GPS campus navigation system from scratch in Python/ROS with ENU projection, Dijkstra planner, and a pure-pursuit follower routing over a 45-building graph, completing routes of up to 0.25 miles
- Integrated OmniVLA-edge under the obstacle avoidance system to navigate unknown environments, with an 85% success rate for goals up to 5 meters
Project Lead
ACM@UCR:Forge
Apr 2026 - Jun 2026
- Led 10 members across 5 sub-teams to deliver an AI-powered surveillance system, coordinating Python and Next.js development to launch a functional prototype 2 weeks ahead of schedule
- Mentored team members on YOLOv8, Python multithreading, and MQTT, boosting technical onboarding
- Oversaw the development of a Next.js dashboard to display live camera feeds and YOLOv8 detections
Lead Game Developer
GameSpawn
Sep 2025 - Jan 2026
- Led a team of 3 developers to design and build a multi-level Unity game, using Agile sprints and Git for version control, and set technical direction that enabled on-time delivery
- Developed 7 interactive levels using C#, implementing core gameplay mechanics and player navigation systems
- Designed the game to support both virtual reality (Oculus) and PC platforms, ensuring cross-platform compatibility and expanding the potential player base
Jacob McLaughlin
mclaughlinjacob2005@gmail.com